Overview
I built the software for an autonomous hospital delivery robot, which was later adapted for datacenter inspection. It includes navigation, simulation, a server on the robot and a web console for the operator.
Videos and images
Details
Robot software
The robot is a Clearpath Husky with ROS 2 and Nav2. I built the navigation setup, the mapping, and a server on the robot (FastAPI) that connects the robot to the web console. Production and development versions run as separate services so that changes can be tested without stopping the robot.
Operator console
The console is a React web app that works on a phone and on a desktop. The operator selects a destination on the map, follows the robot and its camera, and can stop it at any time.
Simulation
The same software runs against a simulated hospital and a simulated datacenter hall in MuJoCo and Gazebo. This was used to test multi-room deliveries and inspection routes before running on the robot.
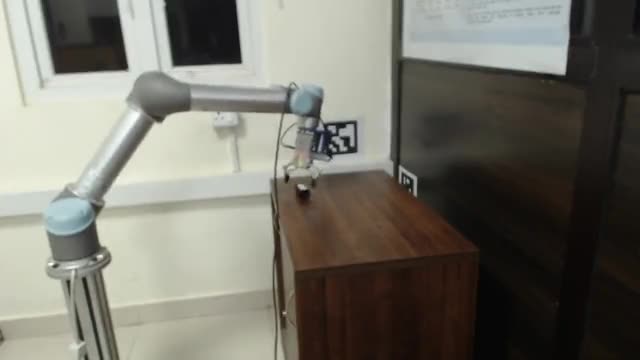 Sim-to-real manipulation with Gaussian-splat simulation
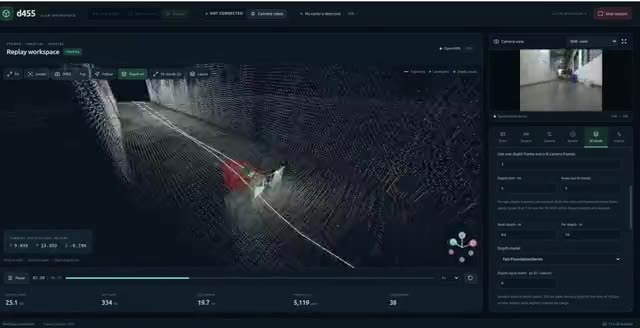 Stereo-inertial SLAM and monocular VIO
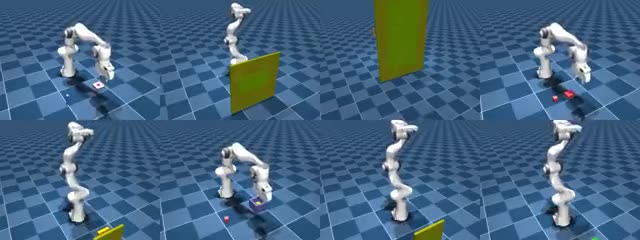 Continual learning for manipulation
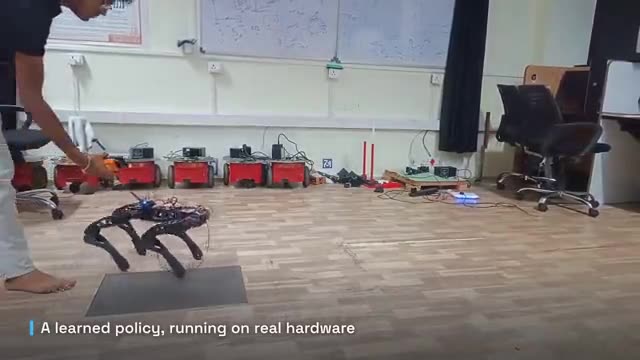 Custom quadruped robot
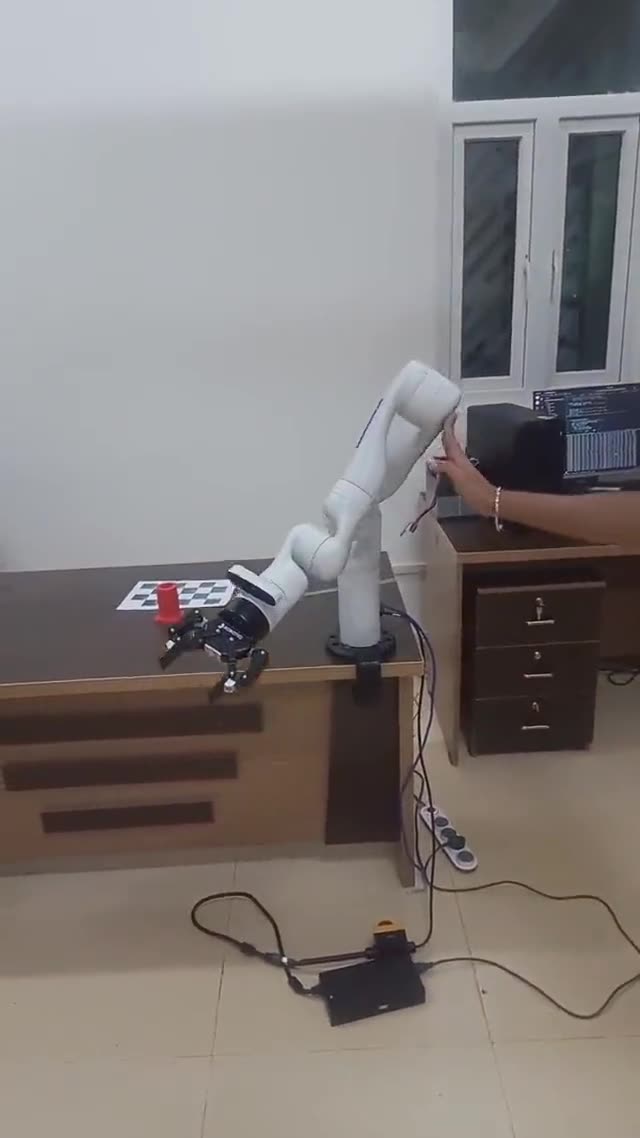 Manipulation control and teleoperation
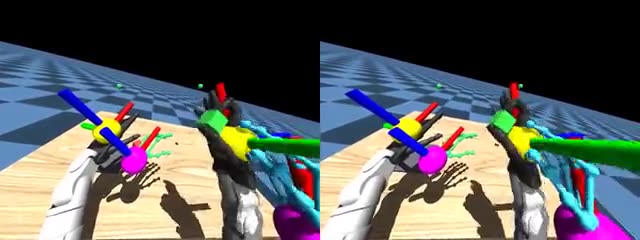 Humanoid manipulation
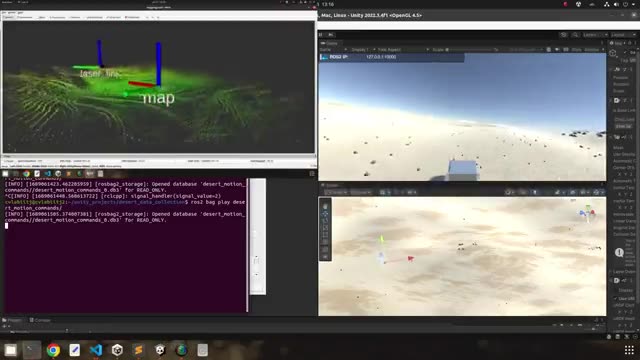 Simulation projects