Overview
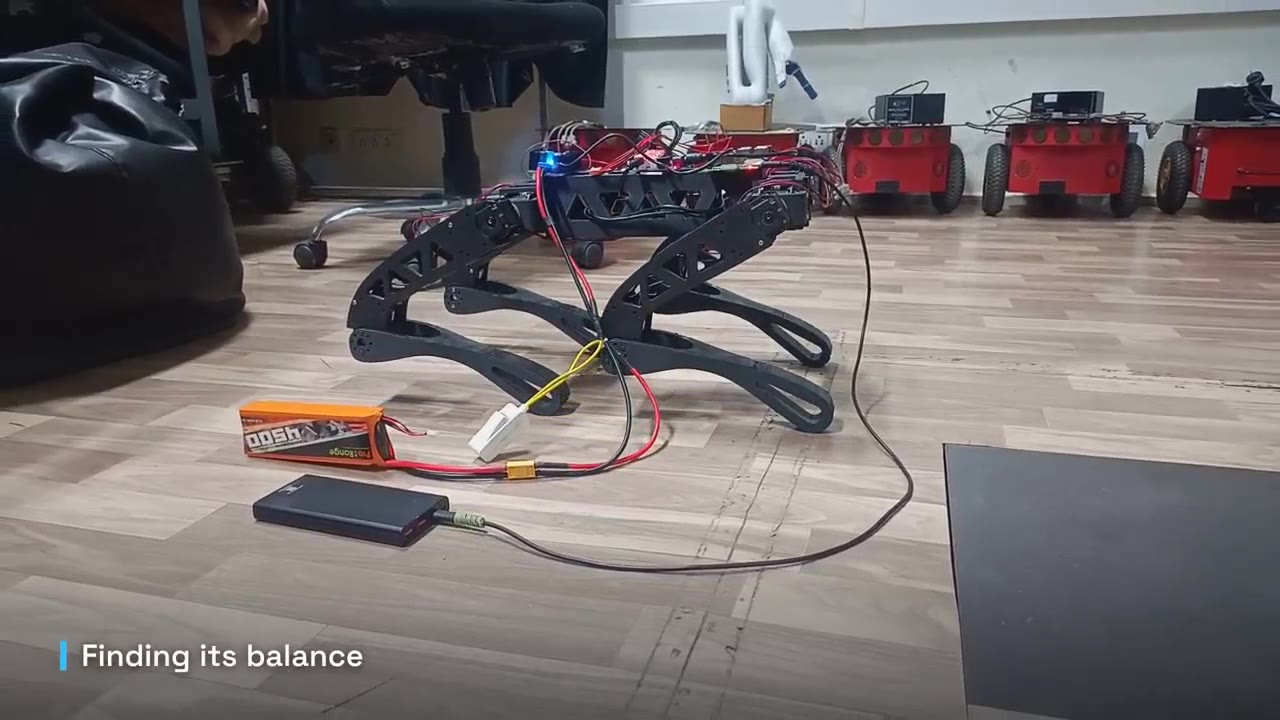
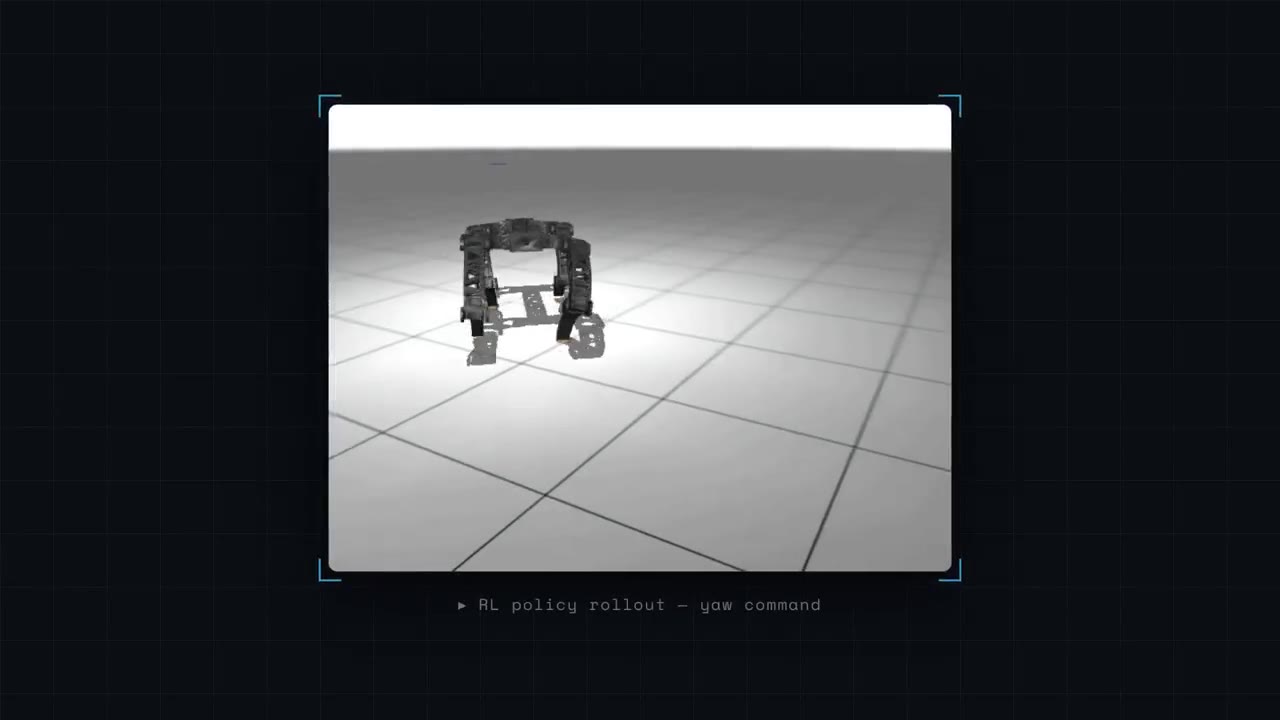
I designed, 3D-printed and assembled a 12-joint quadruped. The walking policy is trained with reinforcement learning in MuJoCo and transferred to the robot. The robot walks untethered at 0.3 m/s and did not fall in the recorded trials.
Videos and images
Details
Hardware
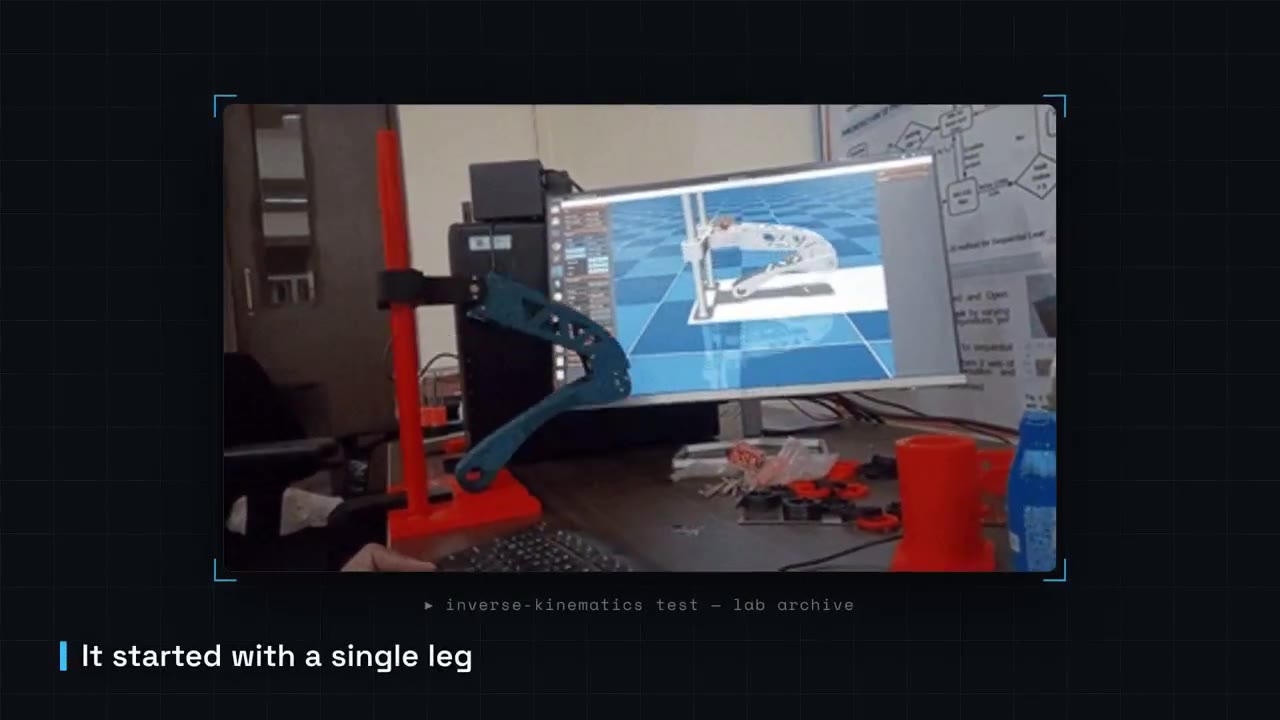
The robot has 12 joints, three for each leg. I designed the leg mechanism and the body in CAD and printed the parts on a 3D printer. The first tests were done with a single leg on a stand to check the inverse kinematics.
Modelling
To make the simulation match the robot I measured the actuators. I sent chirp signals to the joints and fitted an actuator model to the response. The error of the fitted model was 0.061 rad (RMSE). The IMU sometimes stopped sending data for 1.9 to 3.7 seconds, so I added the same kind of gaps to the simulation during training.
Training and transfer
The walking policy is trained with reinforcement learning in MuJoCo and then run on the robot without further training. The robot walks untethered at 0.3 m/s. It did not fall in four trials at 0.3 m/s and one trial at 0.5 m/s.
Simulation with scanned scenes
I also tested the robot in simulation inside scenes reconstructed with Gaussian splatting.
 Sim-to-real manipulation with Gaussian-splat simulation
 Stereo-inertial SLAM and monocular VIO
 Continual learning for manipulation
 Manipulation control and teleoperation
 Humanoid manipulation
 Hospital delivery and inspection robot
 Simulation projects