Simulation projects
Overview
Simulation environments I built for different projects: a desert environment with a 3D LiDAR model in Unity, deformable objects in Isaac Sim, and MuJoCo models of new mechanisms.
Videos and images
Details
Desert simulation with 3D LiDAR
As a Junior Research Fellow at IIT Jodhpur in 2023 I built a Unity simulation of a desert environment for collecting sensor data. I wrote a 3D LiDAR sensor model for Unity that publishes point clouds to ROS. The LiDAR package is public on GitHub.
Deformable objects
Environments in Isaac Sim for deformable objects such as cables and plants, used for testing manipulation.
Mechanisms in MuJoCo
I converted a six-axis parallel robot from a CAD assembly into a MuJoCo model with closed kinematic chains. I also modelled a two-axis handle driven by quasi-direct-drive actuators.
Quadcopter
Trajectory tracking with a quadcopter in a motion-capture room, from my earlier work on aerial robots.
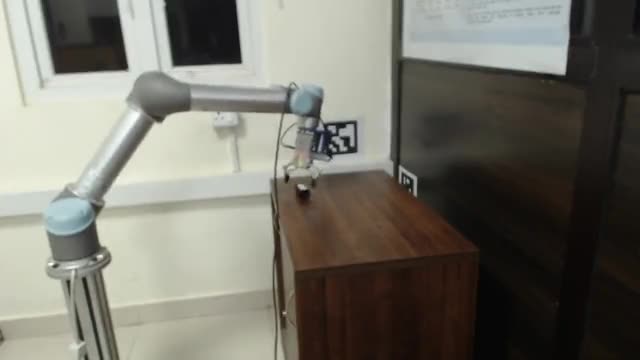 Sim-to-real manipulation with Gaussian-splat simulation
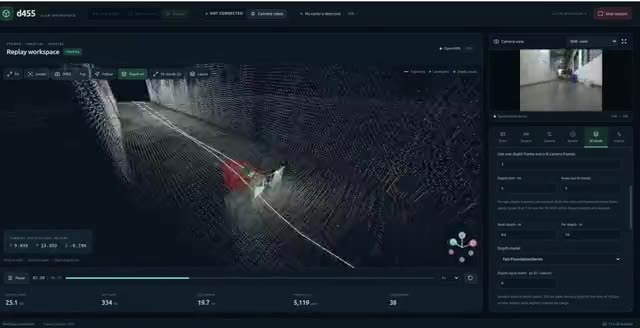 Stereo-inertial SLAM and monocular VIO
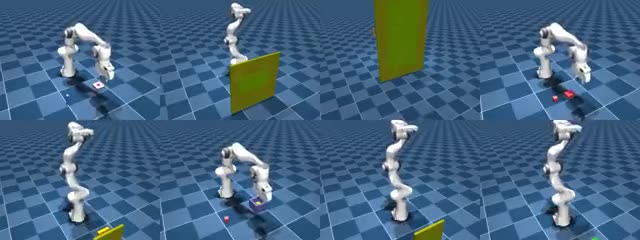 Continual learning for manipulation
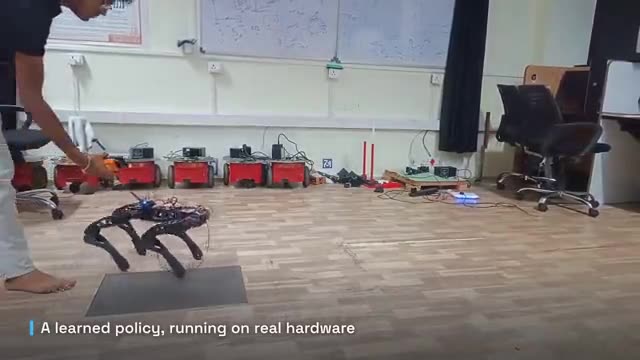 Custom quadruped robot
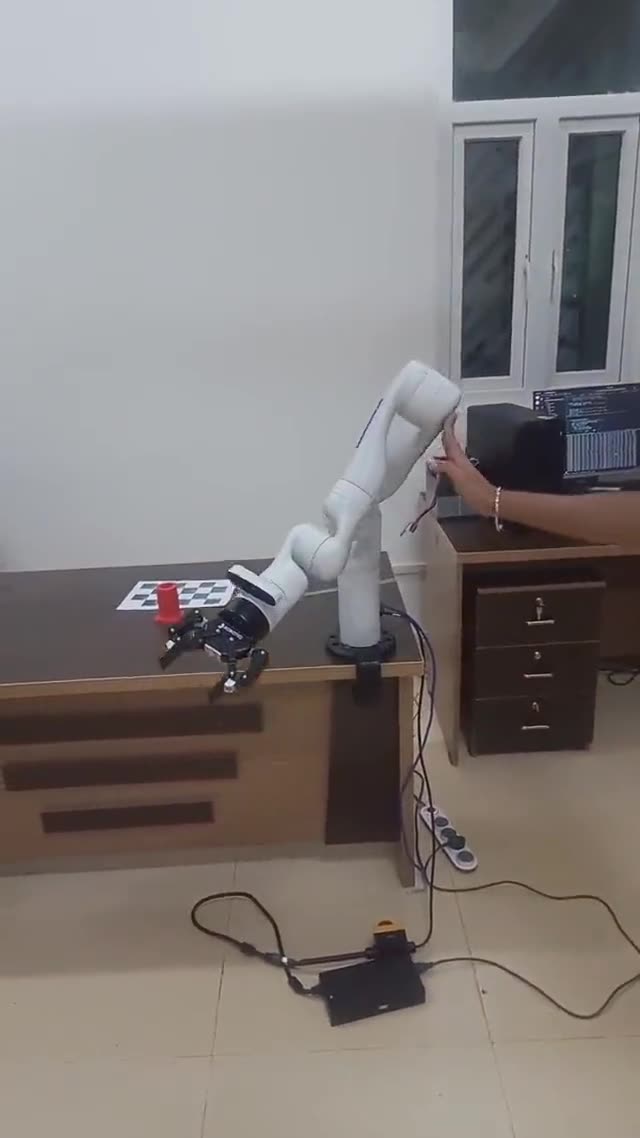 Manipulation control and teleoperation
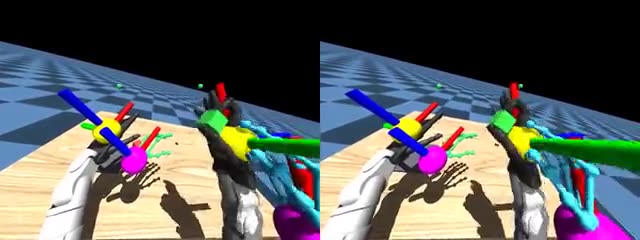 Humanoid manipulation
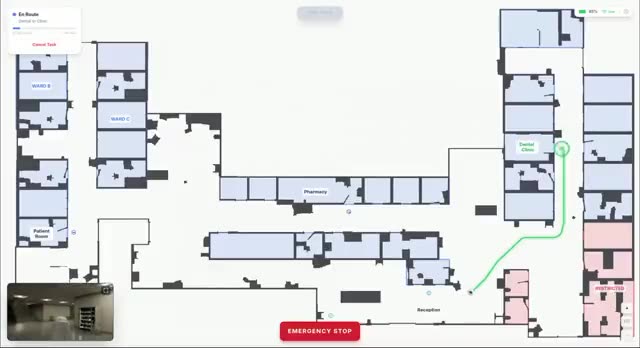 Hospital delivery and inspection robot